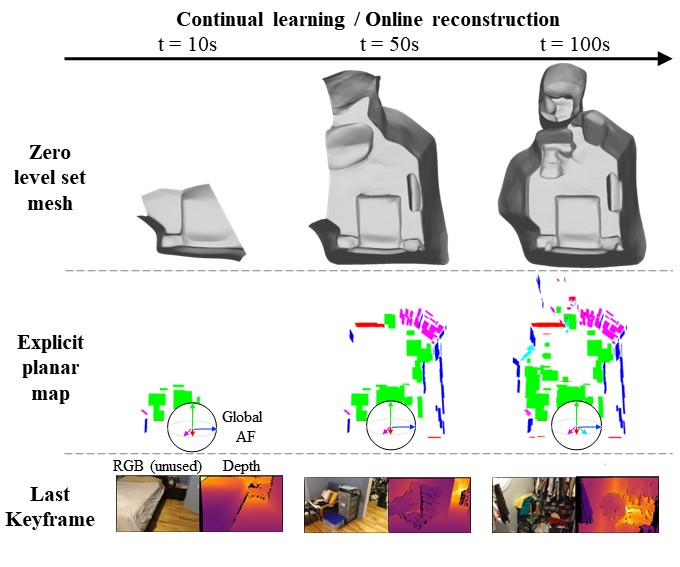
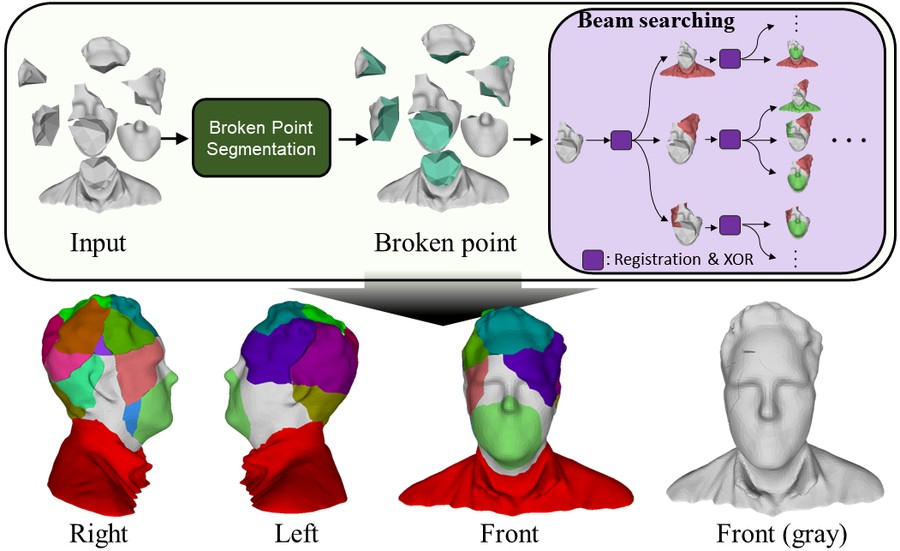
I am interested in SLAM, 3D reconstruction, and collaborative robot perception. My research connects geometric foundation models with consistent online mapping, neural scene representations, and learning across heterogeneous robots.
I also enjoy building robotic systems—from autonomous driving and embedded control to interactive computer vision.
Research
Selected publications. An asterisk (*) denotes equal contribution.
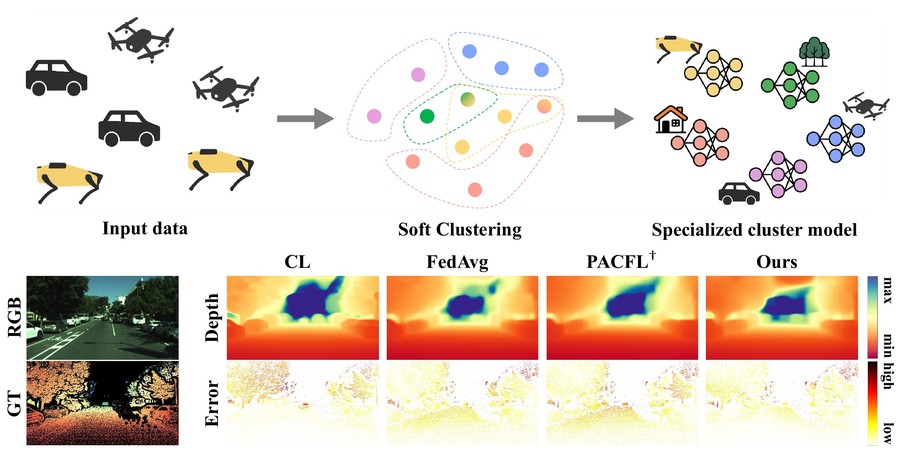
Uses descriptor-based soft clustering to learn depth estimation across heterogeneous robots, environments, and sensing conditions without transferring raw data.
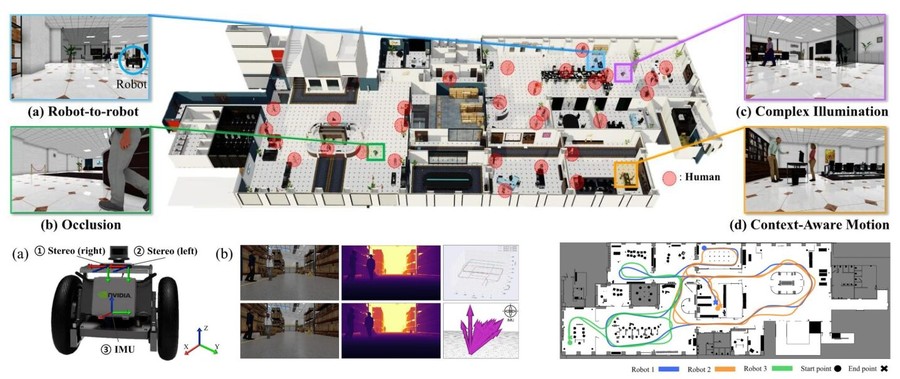
A synchronized multi-robot benchmark built in NVIDIA Isaac Sim, with three robots in hospital, office, and warehouse environments and paired static/dynamic sequences.
2020 · 4th-year undergraduate · Team Development Lead
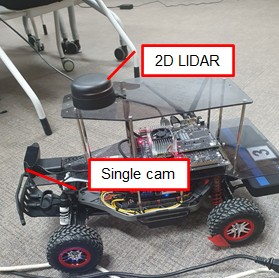
Led team development of path planning and vehicle control for the 2020 university creative-car competition. Integrated global reference paths prepared in QGIS, Pure Pursuit tracking, parking, static-obstacle avoidance with a local grid map and candidate paths, emergency braking, and traffic-light handling.
Technologies: C++ · Python · ROS · Vehicle control · Local planning · Global path planning · Pure Pursuit
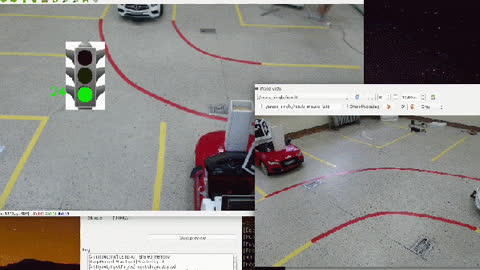
Developed cooperative intersection driving using vehicle-to-infrastructure (V2I) communication and camera perception. Localized vehicles with ArUco markers relative to a traffic-light camera and demonstrated collision avoidance in red-light-violation scenarios.
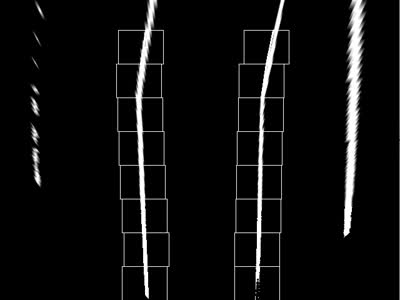
Developed a ROS vision pipeline that transforms camera images into a bird’s-eye view, parameterizes lane lines in cylindrical coordinates, detects white and yellow lanes with sliding-window RANSAC, and generates waypoints for lane following.
Technologies: C++ · ROS · Computer vision · RANSAC
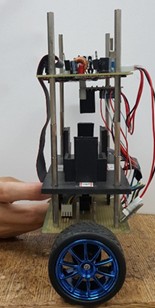
Built a self-balancing robot that computes a balance error from a six-axis motion sensor and uses PID feedback to control stepper motors through an ARM Cortex-M microcontroller.
Technologies: C++ · ARM Cortex-M · PID control · Six-axis motion sensing · Stepper motors
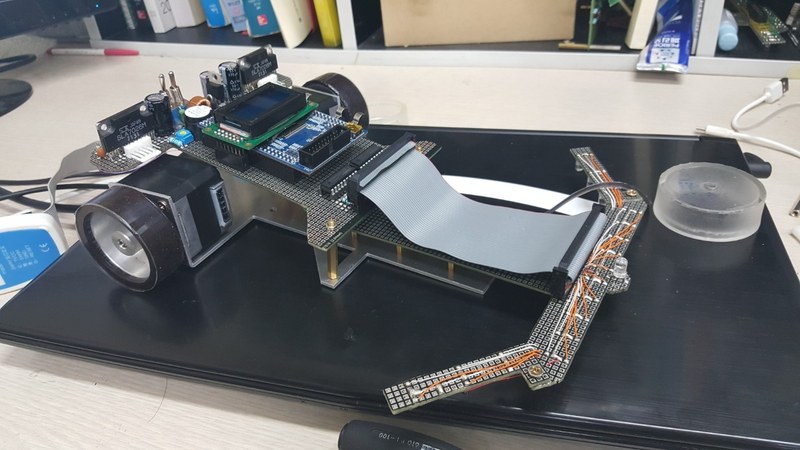
Built an STM32 / ARM Cortex-M line-following robot with hand-built hardware, infrared sensors, stepper motors, and PID steering and speed control. The project reports running speeds of 1.5–2.4 m/s.
Technologies: C (embedded) · ARM Cortex-M · STM32 · Infrared sensing · PID control · Hand-built hardware
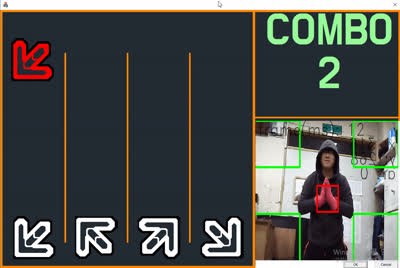
A camera-based rhythm game controlled by hand motion. Color segmentation and histogram backprojection detect the hands, while Mean Shift tracks them for interactive gameplay.
Technologies: C++ · OpenCV · MFC · Mean Shift tracking